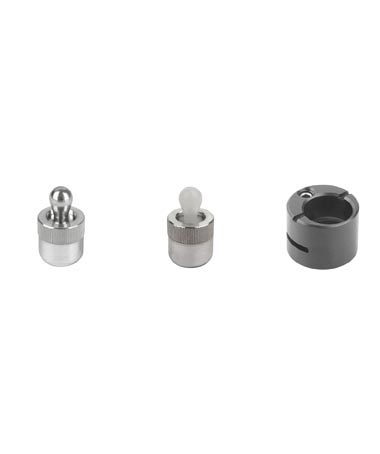
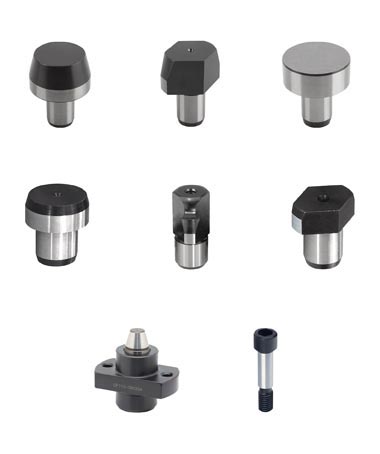
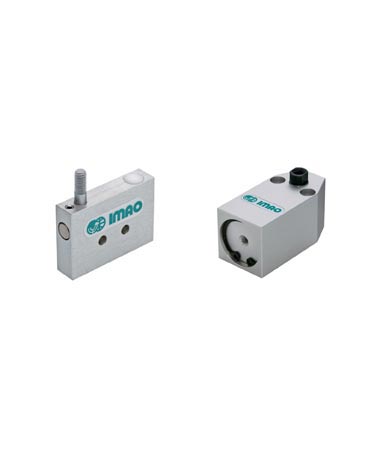
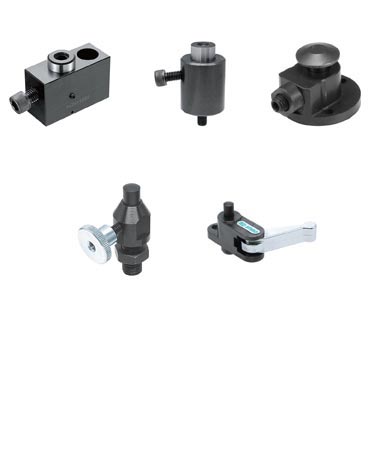
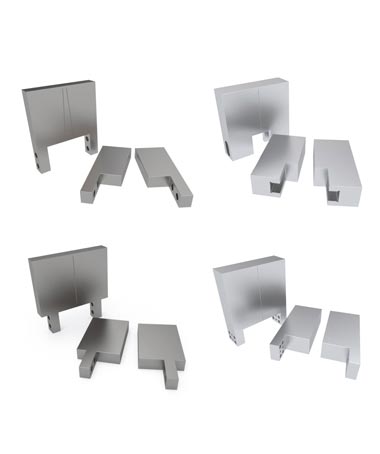
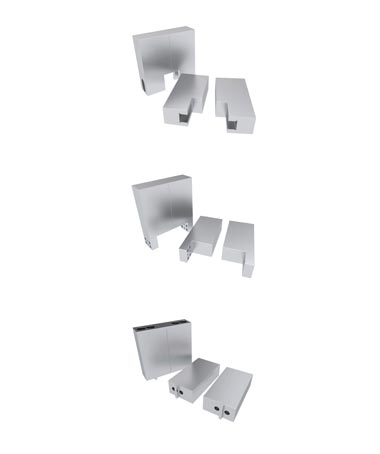
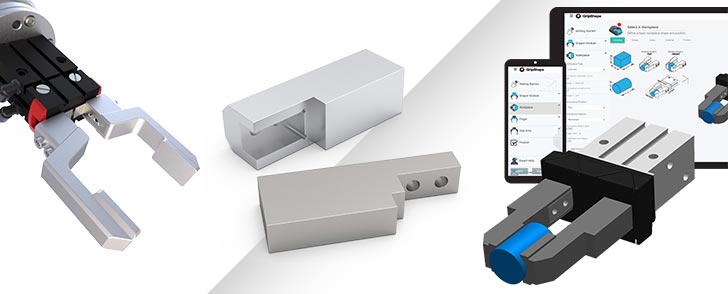
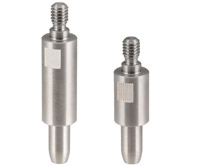
One Gripper For a Variety of Workpieces
Change Gripper Fingers with Simple Robot Arm Motion
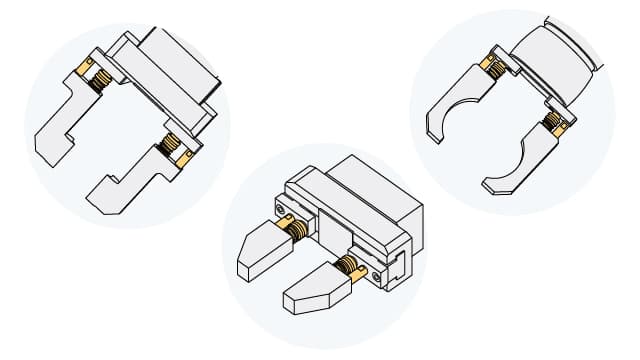
To handle a variety of workpieces with a single robot, common approaches include using a tool changer to replace the entire gripper or a dual-gripper setup to perform multiple tasks. While these solutions offer flexibility, they often require multiple grippers and can result in a larger, more complex system.
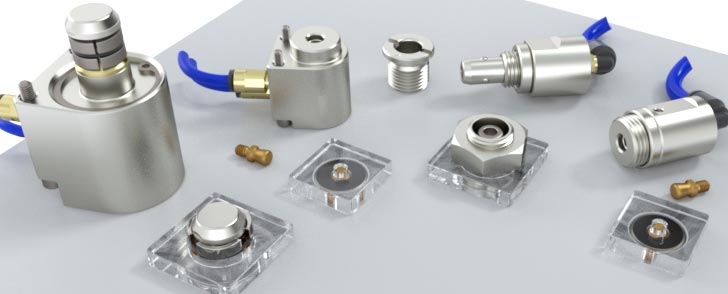
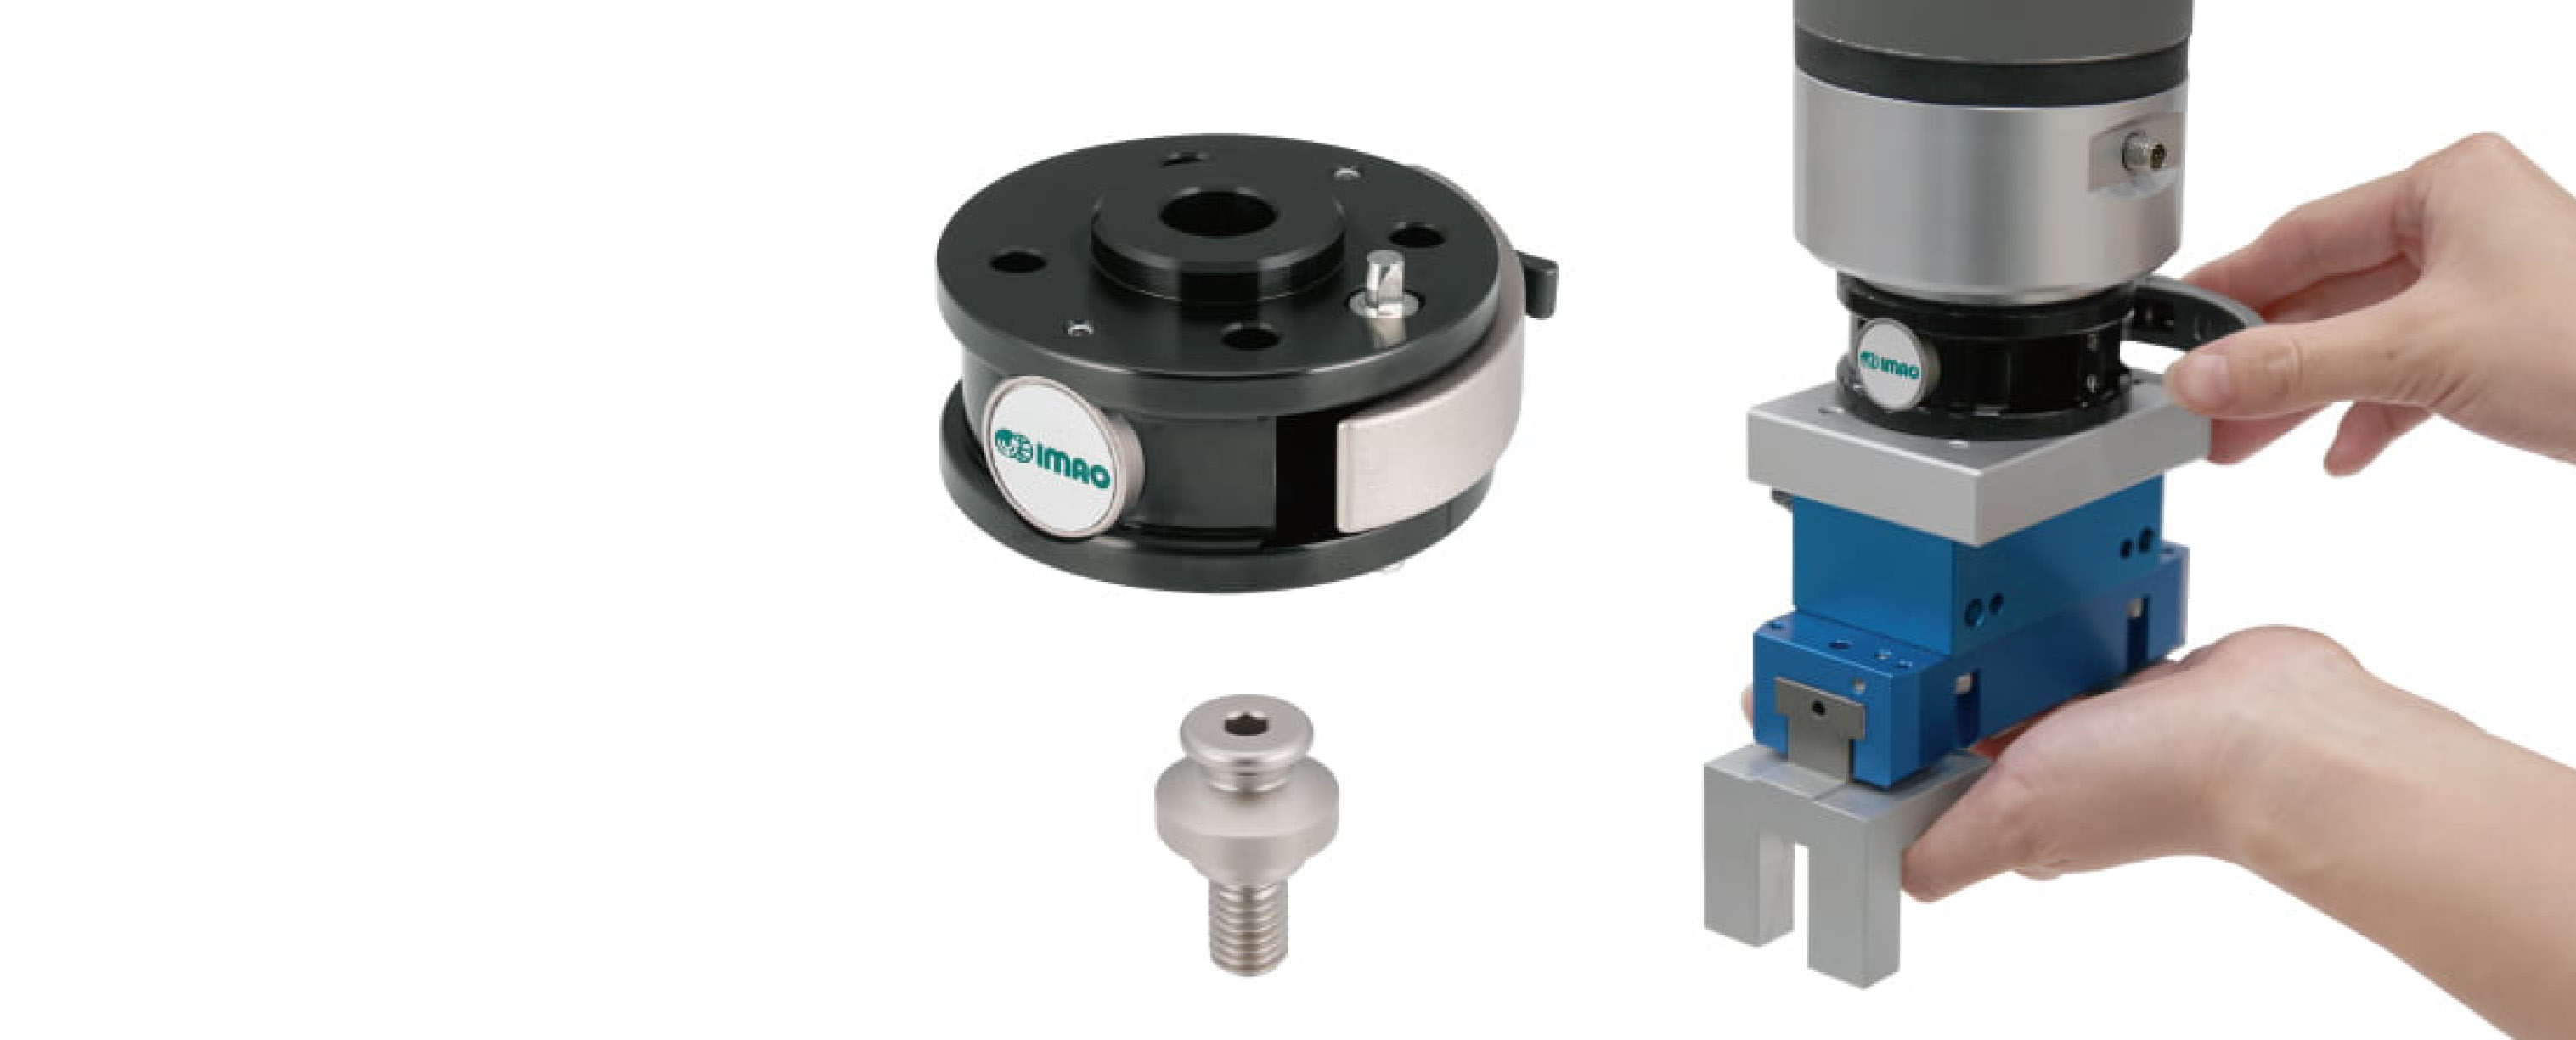
MotionAct Finger Changers offer another option: changing only the gripper fingers.
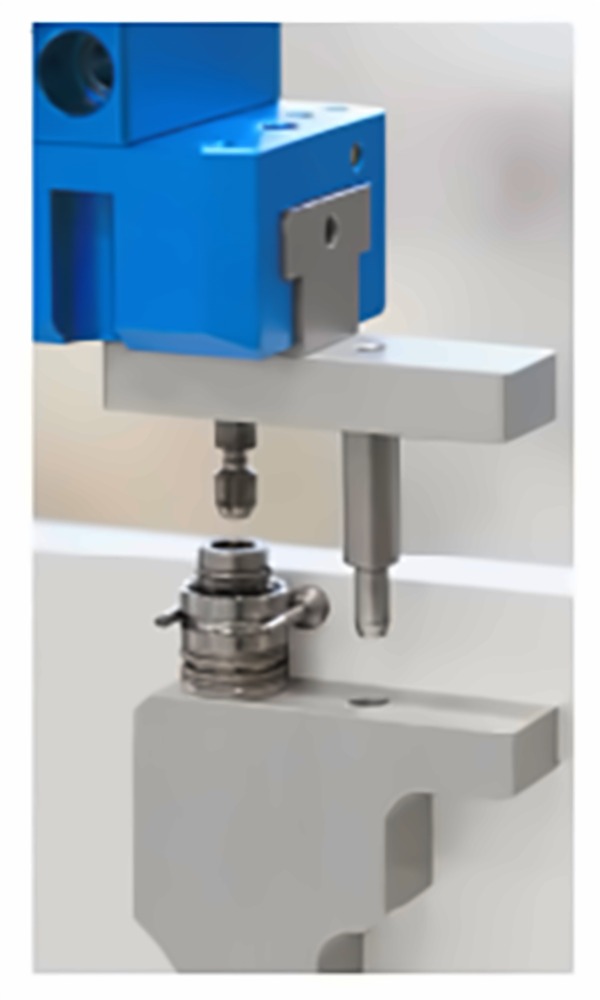
These mechanical fastening components enable gripper finger changes through simple robot arm movements.
By enabling automated finger changes to suit different workpieces while keeping the same gripper, MotionAct Finger Changers provide a flexible, cost-effective system.
MotionAct Finger Changer Features
Quick Finger Changes with Simple Robot Arm Motion
The gripper fingers lock and unlock through simple robot arm movements, so finger changes can be built right into your product changeover sequence.
The result is quick, automated finger changes with no manual replacement.
Compatible with a Wide Range of Grippers
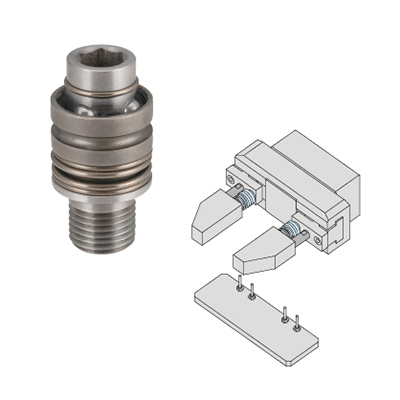
The mounting plate can be tailored to suit the gripper, so MotionAct Finger Changers work with a wide variety of grippers. Any gripper that can accommodate the clamping pin can be used.
With no need for a specific manufacturer or dedicated gripper, it’s a simpler, more cost-effective alternative to systems that replace the entire gripper.
Secure Mechanical Locking
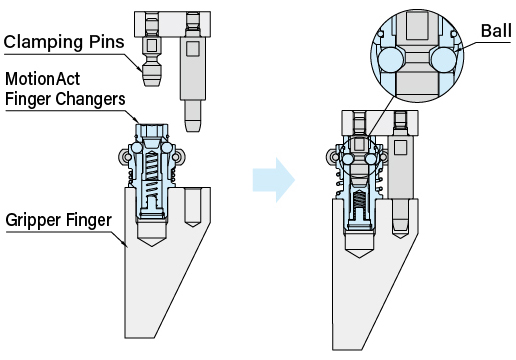
When the clamping pin is inserted into the Finger Changer, internal balls engage and retain it. The ball-and-taper mechanism locks the finger firmly in place until it’s released using the retaining pin and robot arm movement.
Built on IMAO’s expertise in mechanical fastening, the lock needs no electrical wiring or air piping to operate.
Compact and Lightweight for Small Robots
Because only the gripper fingers are changed, not the entire gripper, the changeover system stays compact, giving you more flexibility in equipment layout.
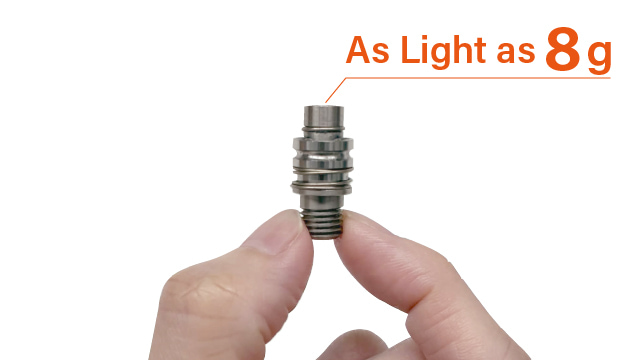
Its light weight also minimizes the impact on robot payload capacity, making it well suited for small robots with limited payload.
Application Examples
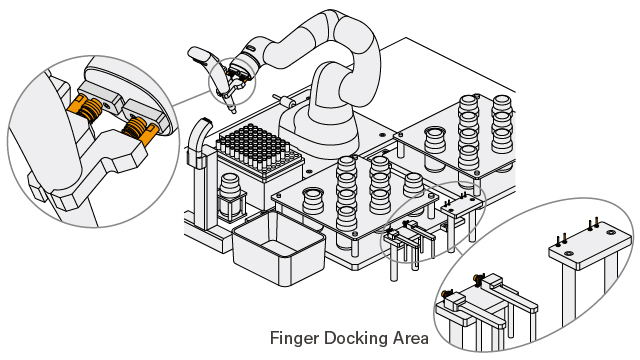
Gripper Finger Change in a Laboratory
Gripper fingers can be changed to suit the tools or workpieces being handled, enabling flexible automation of multiple tasks with a single small robot.
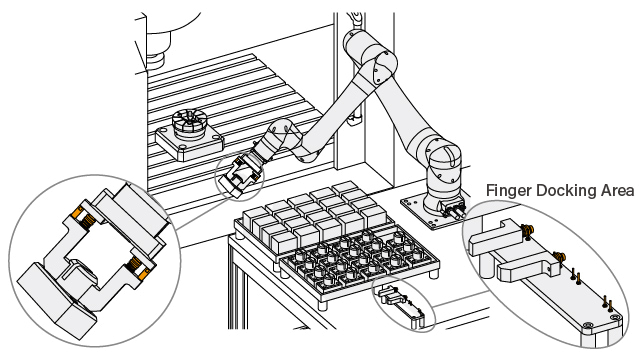
Gripper Finger Change for Machine Tending
Gripper fingers can be changed automatically to suit different workpieces, enabling automated machine tending for high-mix production.
Finger Changer System Components
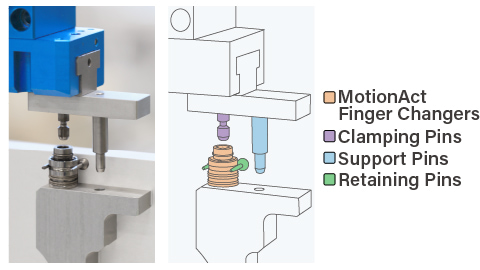
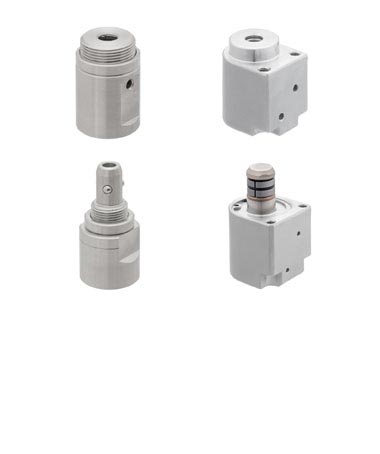
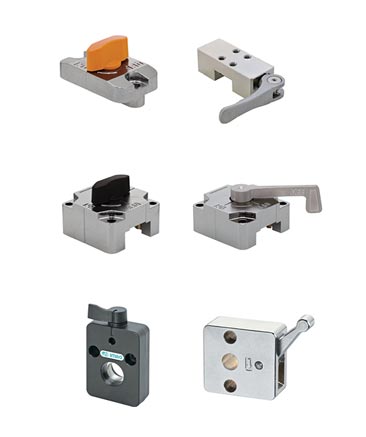
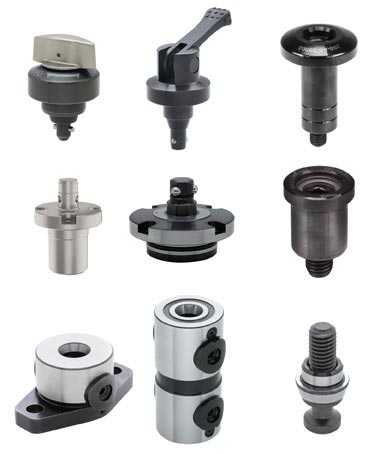
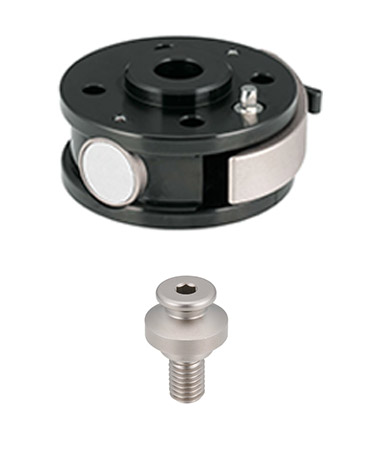
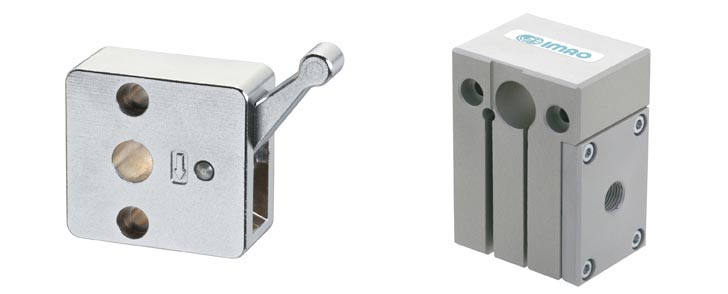
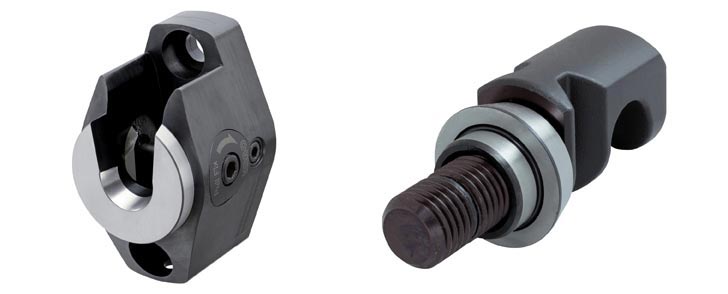
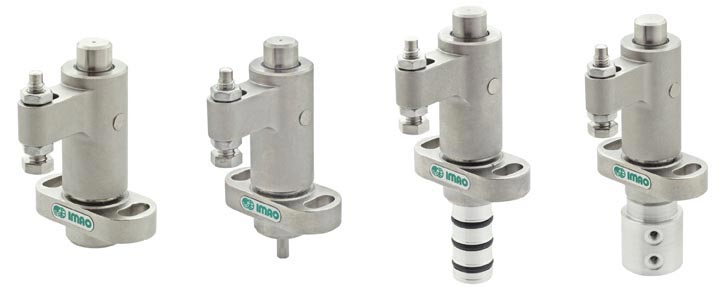
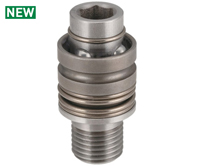
QMCF MotionAct Finger Changers
- Mechanical locking units that receive and lock the Clamping Pin to secure the gripper finger to the gripper.
- The mechanical locking mechanism uses spring force and requires no air or electrical power.
- QMCF Datasheet
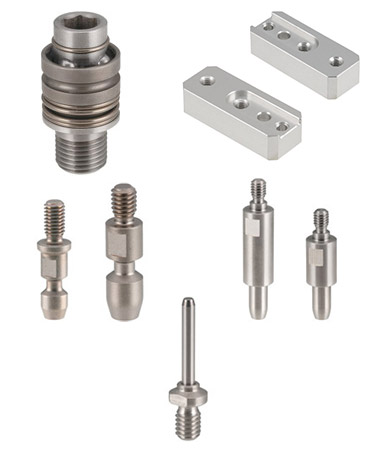
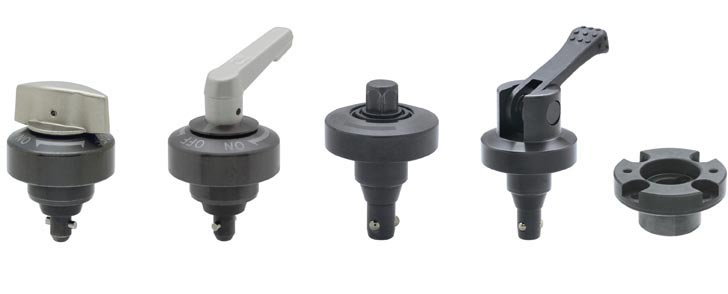
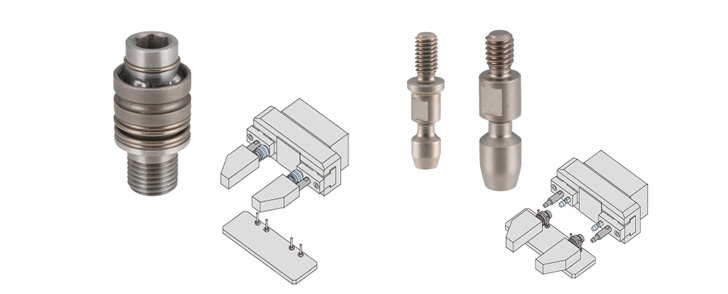
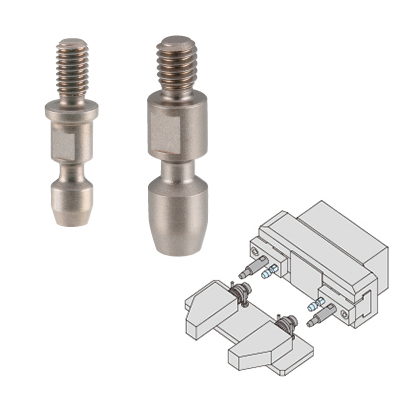
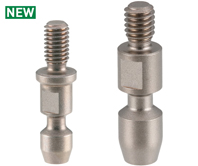
QMCFC Clamping Pins
- Pins inserted into the Finger Changer.
- With a mounting plate designed to suit the gripper, they can be mounted on a wide range of grippers.
- QMCFC Datasheet
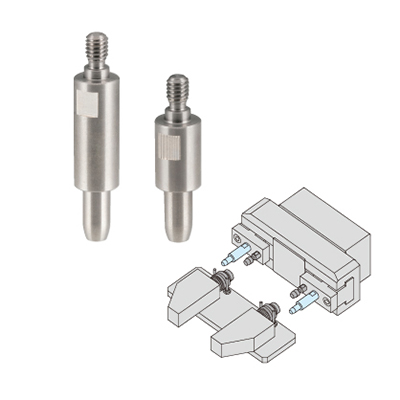
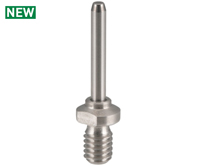
QMCFS Support Pins
- Pins that support loads applied to the gripper finger.
- Using two Support Pins per finger improves positioning accuracy.
- QMCFS Datasheet
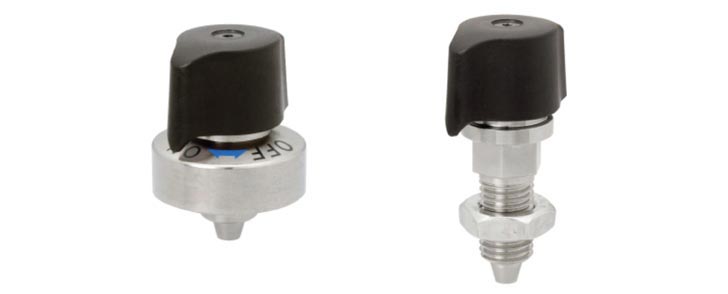
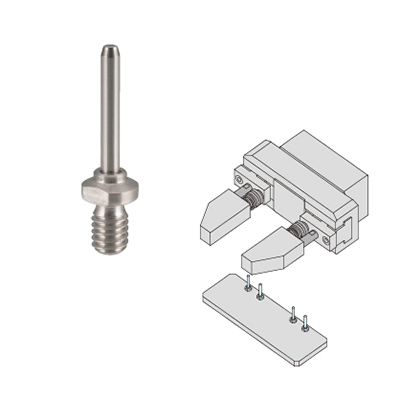
QMCFE Retaining Pins
- Pins that engage the groove on the Finger Changer body to hold it in place.
- During removal, they provide a support point, allowing the Finger Changer to be disengaged through robot arm movement.
- QMCFE Datasheet
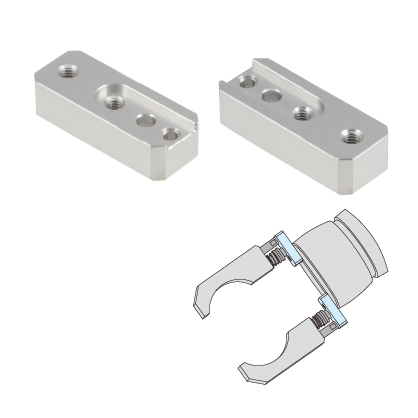
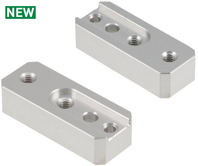
QMCFP Mounting Plates for COBOTTA
- Mounting plates designed for installing the pins on COBOTTA’s optional electric gripper.
- For use with the QMCF0411-15-SUS Finger Changer.
- QMCFP Datasheet
 View Cart {{shoppingcart.totalQuantityDisplay}} Item(s)